Week #4


Below is my first and second working simulation in week 4, we can see big progress in work, the robot got few new options

Goal – First time we can set the goal
End of the program – If we reach the goal


The robot is divided into two parts on the right-side range of the direction goes from (front 0 to back 180) on the left direction goes from (front -0 to back -180) we can use both 180 and -180 it doesn’t change anything.
When finding a wall we decide where we want to go (left-right) it chooses it by calculating direction in which way the goal is if it is more then 0 then its right otherwise left. Then we follow the wall until we reach the end or find the corner. If we find a corner we are changing the wall that we follow to the new one. If we find the end of the wall we try to go on the other side of the wall.
Week #3

Above is my first working simulation in week 3, we can see big progress in work, the robot got few new options:
Scanners ultrasonic
object avoidance

Problems:
My code from last week in which one I said that I can specify from which set of feet I will start, is good but it starts to move the robot to one side, so to compensate that I use alternating leg movement(Start from (1,3,5) then do the same by using(2,4,6))

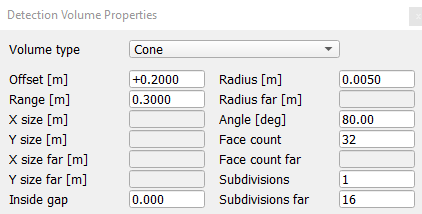
Another problem was with reading sensors it’s hard to find out how far sensors should reach and how big cone should be.

Cone
Offset -> How far away it starts
Range -> How far it ends
Angle -> From left to right

Another one was about object avoidance, the robot will go forward if nothing is detected, but sometimes we want to go to left like here:
Sim-Screen
We don’t detect anything but if we go forward we detect wall on the left side which I set to move robot backward, so if we go forward robot will detect wall go back and so on.
I create for this situation some kind of memory, array in which one I specify what was the position of two last objects. If it was in front and on the left then go left otherwise forward.


Progress:
The robot is moving in a sensible way. There are many ways to bug it because we don’t have goal yet. Also in this scenario, walls are mostly connected and there are no hills.

Next week:
The short document still need some adjustments. Next week I will probably create a kind of map system, to keep track of where we start and where are the objects, also I will set the first goal.

Week #2

Above is my first working simulation in week 2, we can see big progress in work, the robot got few options already:
hexapod.body_shift
Stretching/Shifting body

hexapod.step_forward
We can specify which set of the foot will go first and in which direction we are going

hexapod.walk
This function is for providing a walk we set step.length, step_height and how long should it work

Problems:
I spend quite a lot of time to set connection with simulator via a port, the problem was in python which was 32bit version (64bit is needed to read library 64bit).

The complexity of code, right now the robot got only a few options and it is already quite complex in calculations.

Progress:
The robot is moving in a sensible way. It can do right now many moves in any direction this is what I was looking for to obtain as flexible functions as possible.

Next week:
I plan to create a short document about all these functions to provide a kind of specification, and I also plan to add sensors and few behaviors like object avoidance

Week #1

In the first week, I looked on tools that I might use in my project, then after deciding which option will work best for me, I decided that I will use V-rep for simulation and Python for coding, if I would like to create some objects that I can put into V-rep then I will use Fusion 360. In the first week, I also wrote a Project outline that gives me a look on what precisely I want from this project. Then i set up this blog on which i will publish all important informations about current state of this project as well as all problems that occurs with it.

Stwórz swoją własną witrynę internetową, za darmo na WordPress.com.Stwórz swoją własną witrynę internetową.
Zacznij za darmo